
ZHIWEI ZHANG / 张志威
Making robots
smarter.
Exploring embodied AI, robotics, artificial intelligence, and world models—toward robots that perceive their surroundings, understand tasks, learn skills, and act in the real world.
A place for learning, building, and reflection. About me →
BUILD & LEARN
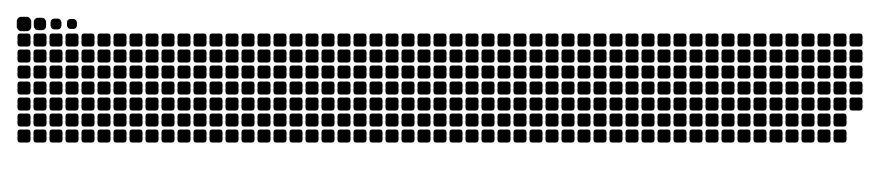
GitHub activity
Recent work, collaboration, and coding habits. Charts are refreshed on a monthly schedule.


Contribution history & community


Recently starred projects

EXPLORE
From curiosity to practice
Following a path through robotics and AI, grounded in programming and engineering.
01 / ROBOTICS
Robotics & ROS2
Building an understanding of robotic systems through modeling, transforms, simulation, and motion planning.
02 / LEARNING
Reinforcement learning
From states, actions, and rewards to value learning, policy learning, and Actor-Critic methods.
03 / ENGINEERING
Programming & engineering
Notes on C/C++, Python, Java, and the engineering problems worth revisiting.
04 / WORLD MODELS
Embodied AI & world models
Exploring how robots represent their surroundings, anticipate change, and learn through interaction.
NOTES
A few notes to start with
Selected writing on robotics, learning, and everyday engineering.
REINFORCEMENT LEARNING · FUNDAMENTALS
How an agent learns
A starting point for understanding reinforcement learning: states, actions, policies, and rewards.
ROBOTICS · MOTION PLANNING
DWA local path planning
Understanding trajectory selection through differential-drive motion and velocity sampling.
ROS2 · ROBOT MODELING
Describing robots with URDF
Links, joints, and robot models: the foundations of visualization and simulation.
DEVELOPMENT · TOOLS
SSH port forwarding
Practical notes on tunneling network traffic through SSH and configuring development proxies.
Turn ideas into code. Keep a record of the journey.
Stay curious. Keep moving.